NVIDIA Shows Developers Building Simulations With GPT-6 Astra and Omniverse
NVIDIA has published seven example projects in which developers use frontier AI models such as GPT-6 Astra together with NVIDIA Omniverse libraries to build simulation applications. According to NVIDIA, developers give natural-language instructions to AI agents, review the results and guide changes.
- NVIDIA published seven projects where developers direct AI agents such as GPT-6 Astra with Omniverse libraries to build simulations.
- Ashley Reid used Astra and Claude Fable 5 agents to create two digital twins and improve two others over about three days.
- In the Robo Olympics experiment, a simulated Unitree G1 humanoid cleared a hurdle in 64 of 100 trials.
- Other projects cover a warehouse humanoid simulator, an autonomous-driving test environment, robotic disassembly, a space station viewer and captured-room testing.
How the workflow works
NVIDIA describes the task of turning a simulation idea into a working application as a chain of steps: assembling assets, connecting physics and rendering, and checking that the scene behaves as intended. Developers are now using frontier AI models to help carry out that work, building applications for exploring scenarios, investigating failures and improving designs.
In the examples, developers direct the agents, while Omniverse libraries supply GPU-accelerated physics, rendering and sensor simulation capabilities. NVIDIA says it will add new examples from its own teams and from developers across the ecosystem.
Robots, vehicles and digital twins
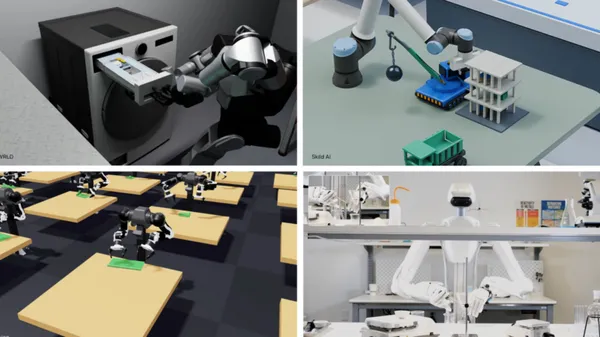
In the first project, Frank DeLise, Omniverse product manager at NVIDIA, used Astra to turn a SimReady warehouse and humanoid robot into an interactive simulator with first- and third-person views. He directed Astra to connect Omniverse libraries for physics (ovphysx), scene updates (ovstage), rendering (ovrtx) and the user interface (ovui). Astra then generated animation and application code.
Doyub Kim, a manager on NVIDIA's simulation technology team, asked Astra to build Zero to Alpamayo, a reusable simulation environment based on San Francisco's Market Street. Astra connected asset creation, traffic, Omniverse RTX sensor simulation and Alpamayo driving in stages, with each integration checked. The prototype serves as a testing ground for comparing models and tracing how scene or sensor changes affect driving behavior. A separate Cosmos3-Nano experiment varied weather and lighting in recorded simulation videos.
Ashley Reid, who works on RTX sensor validation at NVIDIA, directed Astra and Claude Fable 5 agents to compare ovrtx camera and raw LiDAR outputs with recorded data. The agents created two digital twins from scratch and improved two existing ones. Reid guided the iterative workflow over about three days, and acceptance depended on camera and LiDAR metrics.
Sports, disassembly, space and captured rooms
Tae Kim, who leads NVIDIA Omniverse engineering and product, used sports videos and natural-language instructions to guide Astra in building Robo Olympics, an experimental project with simulated Unitree G1 humanoids. Newton Physics Engine simulated behavior, the open source NVIDIA Warp framework accelerated calculations and ovrtx rendered scenes. In one experiment, the robot cleared a single hurdle in 64 of 100 simulation trials.
Jens Jebens, a senior product manager for OpenUSD at NVIDIA, directed Astra to model a car suspension in PTC Onshape and configure it in NVIDIA Isaac Sim. The agent measured the available space and designed a wrench the robot could use to reach the bolts. Jebens reported successful removal of a suspension component in simulation.
Nic Johns, an engineering director at NVIDIA, prompted Astra to assemble NASA assets into an OpenUSD International Space Station model with telemetry. He built the application with a single prompt, then used a follow-up prompt to shift the scene to Earth's daytime side. The workflow used Blender, ovrtx, ovstage and ovstream.
Chirag Majithia, from the Isaac engineering applications team, directed Astra to turn stereo camera captures into an editable OpenUSD studio. The workflow combined PyCuSFM, FoundationStereo and nvblox for reconstruction. Isaac Sim tests guided collision and contact revisions for doors and drawers.
What it means for developers
The examples come from NVIDIA's own staff, so they show what the company considers possible rather than independent results. Still, they outline a pattern: developers set goals and review outputs, while agents connect libraries, generate code and iterate on scenes. NVIDIA presents the approach as a way to link design, sensor data and testing, for example by using measured discrepancies to guide scene improvement or by offering a starting point for robot policy training. The company invites developers with a simulation idea to explore Omniverse libraries and start building with an AI agent.